Draghilev method revisited - Mensajes

Wrote... drawbacks. In linux smath does not work very well. I have all calculations going on the right side of de system. I calculate the coordinates of the tangent point and respectively the rotation speed of the oval. At the tangent point the velocity is zero and a tick icon is observed. ...
Hi grelkin2. I don't have a linux rigth now, and can tell which issue could be that. About the numeric precission, there are two big sorces of numerical errors. First, the arc length, which was "calculated" by eye looking at the graph when the curve closes, given the value of 7.3. This value can be improved numerically by solving an equation that sets the square of the norm between the final and initial points equal to zero. This problem is not difficult to solve.
As comment, this is why I notate in other posts under this topic that one need to divide with the norme of the Dragile system to parametrize about the arc lenght.
The second major source of error is considering the minimum of the entire curve only by taking into account a few points: only 31 for each rotated figure, from which the minimum is selected at each iteration. It could be improved by considering many more points, but it would be very slow and impractical, so it would be necessary to interpolate assuming a smooth curve, but it would require many steps to achieve this.
Finally, rkfixed is used, which is the least accurate of the wide variety of ode solvers available.
Best regards.
Alvaro.

WroteHi grelkin2. I don't have a linux rigth now, and can tell which issue could be that. About the numeric precission, there are two big sorces of numerical errors. First, the arc length, which was "calculated" by eye looking at the graph when the curve closes, given the value of 7.3. This value can be improved numerically by solving an equation that sets the square of the norm between the final and initial points equal to zero. This problem is not difficult to solve.
As comment, this is why I notate in other posts under this topic that one need to divide with the norme of the Dragile system to parametrize about the arc lenght.
The second major source of error is considering the minimum of the entire curve only by taking into account a few points: only 31 for each rotated figure, from which the minimum is selected at each iteration. It could be improved by considering many more points, but it would be very slow and impractical, so it would be necessary to interpolate assuming a smooth curve, but it would require many steps to achieve this.
Finally, rkfixed is used, which is the least accurate of the wide variety of ode solvers available.
Best regards.
Alvaro.
Arc length is about 7.335. I changed N is your sm file to 121 points for smooth curves. rkfixed is a reliable basic method, the other methods are needed for optimization or experimentation or have specific uses.
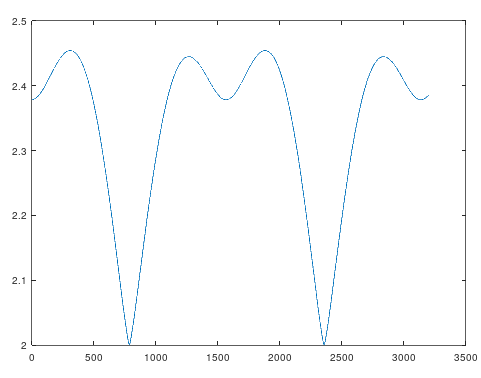
Below is a plot of the translational velocity of the oval at which the velocity at the tangent point is zero.
WroteArc length is about 7.335. ...
This is how Dragilev's method can be used to calculate the arc length of a closed curve numerically. My improvement on Dragilev's method consists in dividing the system of differential equations by its norm to obtain the parameterization of the curves along their arc length. I have not seen this observation anywhere else.

Arc length of a planar closed curve - Dragilev Method.sm (29,44 KiB) descargado 1999 vez(es).
Wrote... I changed N is your sm file to 121 points for smooth curves. rkfixed is a reliable basic method, the other methods are needed for optimization or experimentation or have specific uses. ...
If you say ...
WroteBelow is a plot of the translational velocity of the oval at which the velocity at the tangent point is zero.
Yes, like my approach with 31 points, except that your zero is more zero than mine, which is only an approximation, but a pretty good one, because to detect it you have to zoom in on the graph. There is no numerical method that can withstand a sufficiently large zoom on its graph. It looks like you use more than 3000 points, something SMath couldn't handle in this case. One question: what's the interpration of the values of the x-axis?
Best regards.
Alvaro.

In Mathcad, it seems to me this method with a variable step. When I figure it out as this is done, I will make an update.
WroteYou can configure the method using a rkfixed variable. rkfixed := "RK1", …, rkfixed := “RK6”.
In Mathcad, it seems to me this method with a variable step. When I figure it out as this is done, I will make an update.
Будет замечательно если ты подготовишь модель и рассмотришь зависимость времени вычисления от порядка при заданной точности.
It will be great if you prepare a model and consider the dependence of the calculation time on the order at a given accuracy.
You could have sufficiently large zoom in octave.Wrote
Yes, like my approach with 31 points, except that your zero is more zero than mine, which is only an approximation, but a pretty good one, because to detect it you have to zoom in on the graph. There is no numerical method that can withstand a sufficiently large zoom on its graph. It looks like you use more than 3000 points, something SMath couldn't handle in this case. One question: what's the interpration of the values of the x-axis?
Best regards.
Alvaro.
olv2.mov (161,87 KiB) descargado 472 vez(es).
Value of the x-axis is the number of points at a given accuracy. I changed the accuracy and, accordingly, the number and combined everything in one animation.
olv3.mov (365,73 KiB) descargado 462 vez(es).
WroteYou could have sufficiently large zoom in octave.
olv2.mov (161,87 KiB) descargado 472 vez(es).
If 1000x is enough zoom for you, and make this point zero, it is ok for me too.
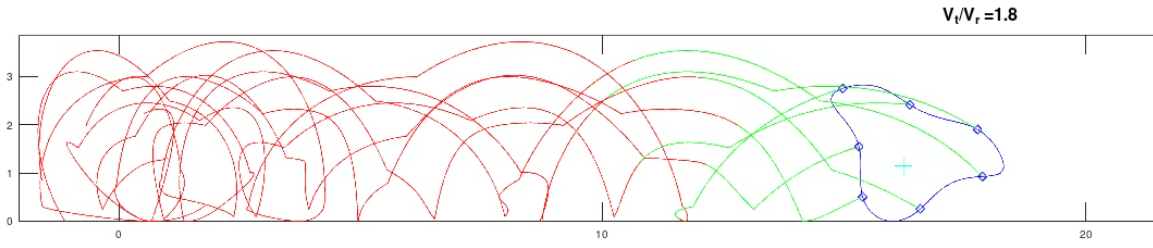
With and without sliding.


Rolling Curve - Dragilev Method.sm (41,71 KiB) descargado 2021 vez(es).
Rolling Curve - Dragilev Method.pdf (262,09 KiB) descargado 1126 vez(es).
Best regards.
Alvaro.
[RUS]В этих замечательных анимациях можно наблюдать движение замкнутых кривых трех видов в зависимости от соотношения скорости движения центра и скорости вращения в точке касания. Движение с пробуксовкой, движение без проскальзывания и движение с проскальзыванием получаются при скорости движения центра меньше скорости вращения в точке касания, равно и больше соотвественно. Владея методом Драгилева можно задавать любой закон движения.Wrote
Best regards.
Alvaro.
Ниже анимация с ускорением скорости движения, при которой можно наблюдать плавный переход между тремя видами движения, описываемых раннее. Также в эту анимацию включил движение без проскальзывания с циклоидоподобными кривыми.[/RUS]
[ENG]In these wonderful animations, you can observe the movement of closed curves of three types, depending on the ratio of the speed of movement of the center and the speed of rotation at the point of contact. Movement with stalling, movement without slippage and movement with slippage are obtained when the speed of movement of the center is less than the speed of rotation at the point of contact, equally and more respectively. Using the Draghilev method, you can set any law of motion.
Below is an animation with an acceleration of the speed of movement, at which you can observe a smooth transition between the three types of movement described earlier. Also included in this animation is a non-slip motion with cycloid-like curves.[/ENG]
olvm.mov (1,21 MiB) descargado 529 vez(es).

Rolling Curve on Curve - Dragilev Method.sm (27,55 KiB) descargado 1994 vez(es).
Rolling Curve on Curve - Dragilev Method.pdf (181,62 KiB) descargado 1169 vez(es).
Best regards.
Alvaro.
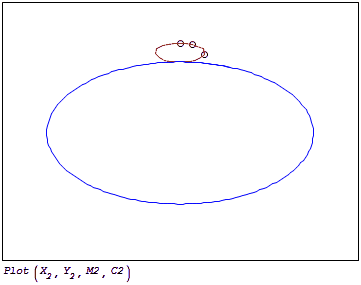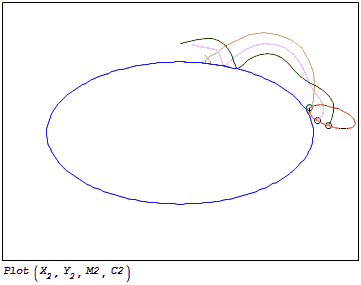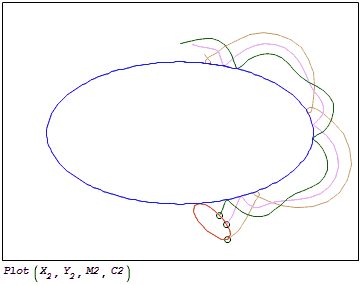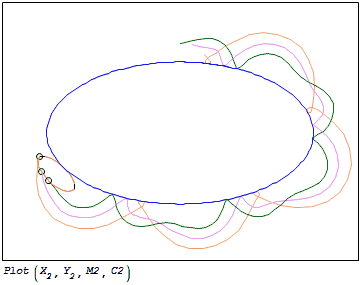
[RUS]Движение эллипса без проскальзывания с поворотом относительно эллипса. Анимация грубая, погрешности большие. Решение получил не точное из системы ду, а комбинированное(сумма нескольких движений)[/RUS]
[ENG]IMovement of the ellipse without slippage with rotation relative to the ellipse. The animation is rough, the errors are large. I got an inaccurate solution from the system of de's, but a combined one (the sum of several movements)[/ENG]
elnel.mov (1,81 MiB) descargado 504 vez(es).
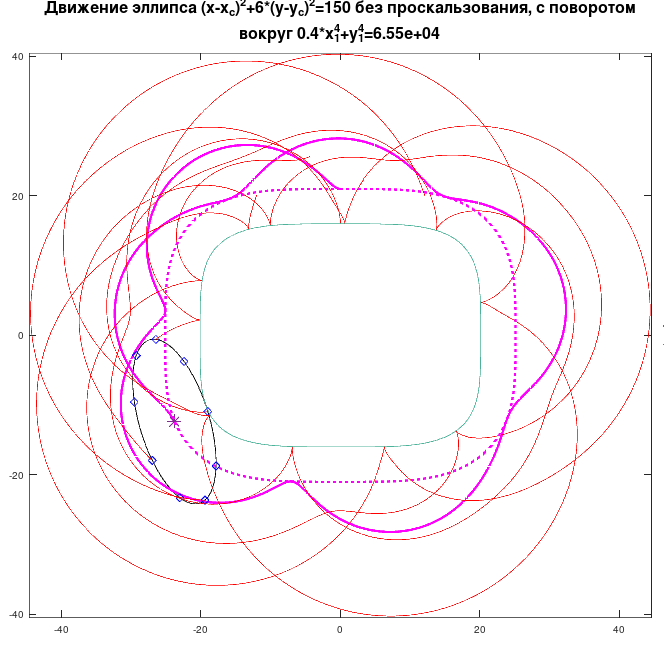
[RUS]Движение эллипса без проскальзывания с поворотом относительно заданной кривой. Улучшенная способ расчета движения точек эллипса только при помощи системы ду. Видно, что центр эллипса движется по некой кривой, зависимой от эллипса и эквидистанты к неподвижной кривой. При окружности центр бугет двигаться по эквидистанте.[/RUS]
[ENG]Motion of an ellipse without slip with rotation with respect to a given curve. An improved way of calculating the motion of the points of an ellipse using the de system only. It can be seen that the center of the ellipse moves along some curve dependent on the ellipse and equidistant to the fixed curve. For a circle, the center of the ellipse moves along the equidistance.[/ENG]
elnkr.mov (811,8 KiB) descargado 473 vez(es).
Система следующая:[/RUS]
[ENG]I considered the problem when an additional condition was added to the system solved using Draghilev's method.
The system is as follows:[/ENG]
x1^2+y1^2-1=0
(x1-x2)^2+(y1-y2)^2-2=0
x1*x2-y1*y2=0
[RUS]Анимация решения ниже[/RUS]
[ENG]Animation of the solution is below[/ENG]
sysbus.mp4 (141,75 KiB) descargado 273 vez(es).
[RUS]Добавим условие, связывающее y1, y2 и новую переменную V0. Получаем новую систему:[/RUS]
[ENG]Let's add a condition linking y1, y2, and a new variable V0. We get a new system:[/ENG]
x1^2+y1^2-1=0
(x1-x2)^2+(y1-y2)^2-2=0
x1*x2-y1*y2=0
y1+y2+V0^2=0
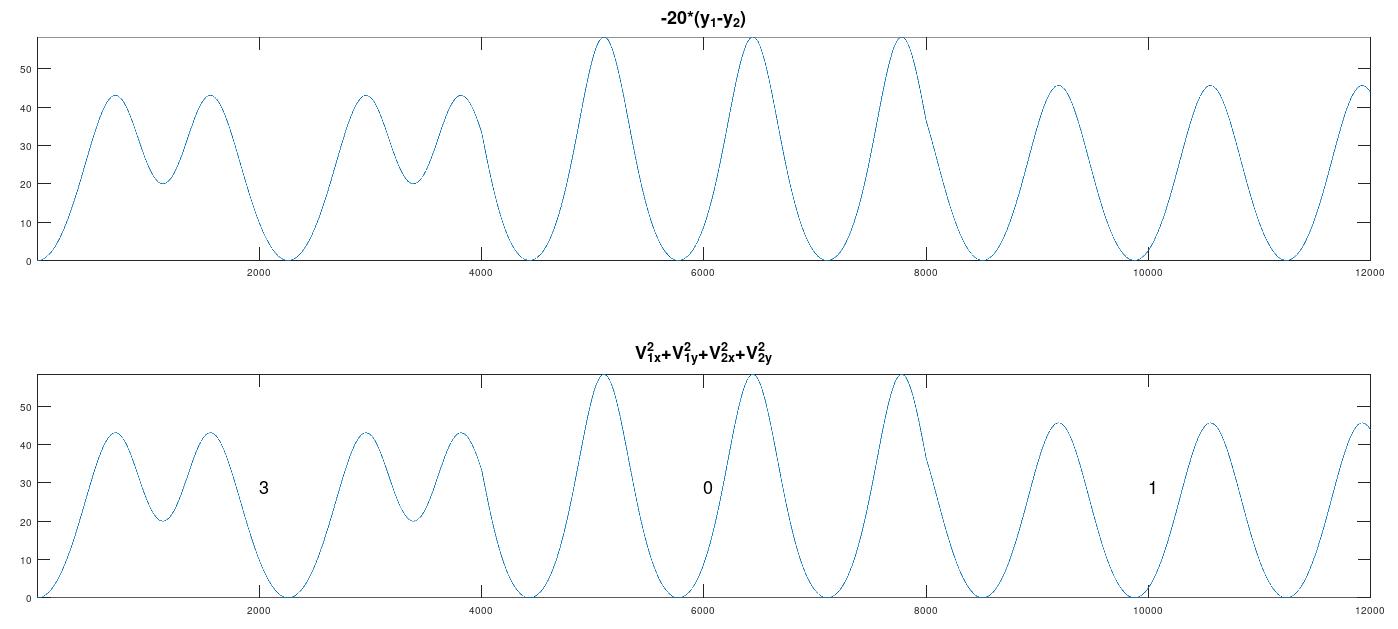
[RUS]Очевидно, что для введенной координаты V0 не выполняется соотношение V0^2=V1x^2+V1y^2+V2x^2+V2y^2. Ниже я привожу графики суммы квадратов скоростей точек 1,2 полученных численно, последнее уравнение делю на две части, которые равны друг другу[/RUS]
[ENG]It is obvious that for the entered coordinate V0, the relation V0^2=V1x^2+V1y^2+V2x^2+V2y^2 is not satisfied. Below are graphs of the sum of the squares of the velocities of points 1 and 2 obtained numerically. I divide the last equation into two parts that are equal to each other.[/ENG]

[RUS]Если использовать специальную норму и поделить всю правую часть систему ду на эту норму, тогда можно получить тождественные графики. Квадрат введенной переменной будет равен сумме квадратов скоростей точки 1 и 2. Привожу ниже графики и анимацию решения[/RUS]
[ENG]If we use a special norm and divide the entire right side of the system de by this norm, we can obtain identical graphs. The square of the introduced variable will be equal to the sum of the squares of the velocities of points 1 and 2. Below are graphs and an animation of the solution.[/ENG]

sysusn.mp4 (195,36 KiB) descargado 255 vez(es).
В анимации угловая скорость o-шарнира изменяется по заданному правилу. В начале она равна 3, потом 0, потом 1. [/RUS]
[ENG]Animation of a controlled two-link joint with the addition of an energy conservation condition using the Draghilev method.
In the animation, the angular velocity of the o-joint changes according to a specified rule. At the beginning, it is equal to 3, then 0, then 1.[/ENG]
[RUS]Скорее мгновенная угловая скорость меняется, но по анимации видно, что совокупная угловая скорость постоянная.
Для случая когда она равна 3-м, на один полуоборот ^-шарнира приходится 3 полуоборота о-шарнира и так далее. [/RUS]
[ENG]The instantaneous angular velocity changes rapidly, but the animation shows that the total angular velocity remains constant.
When it is equal to 3, one half-turn of the ^-joint corresponds to 3 half-turns of the o-joint, and so on.[/ENG]
upr2sh.mp4 (870,34 KiB) descargado 30 vez(es).
- Nuevos mensajes
- Sin mensajes nuevos